2022 · Robotic Painting / Physical Computing
Robot Painting System
A hand sets the arm’s path; the robot repeats it in paint.
Portfolio working title
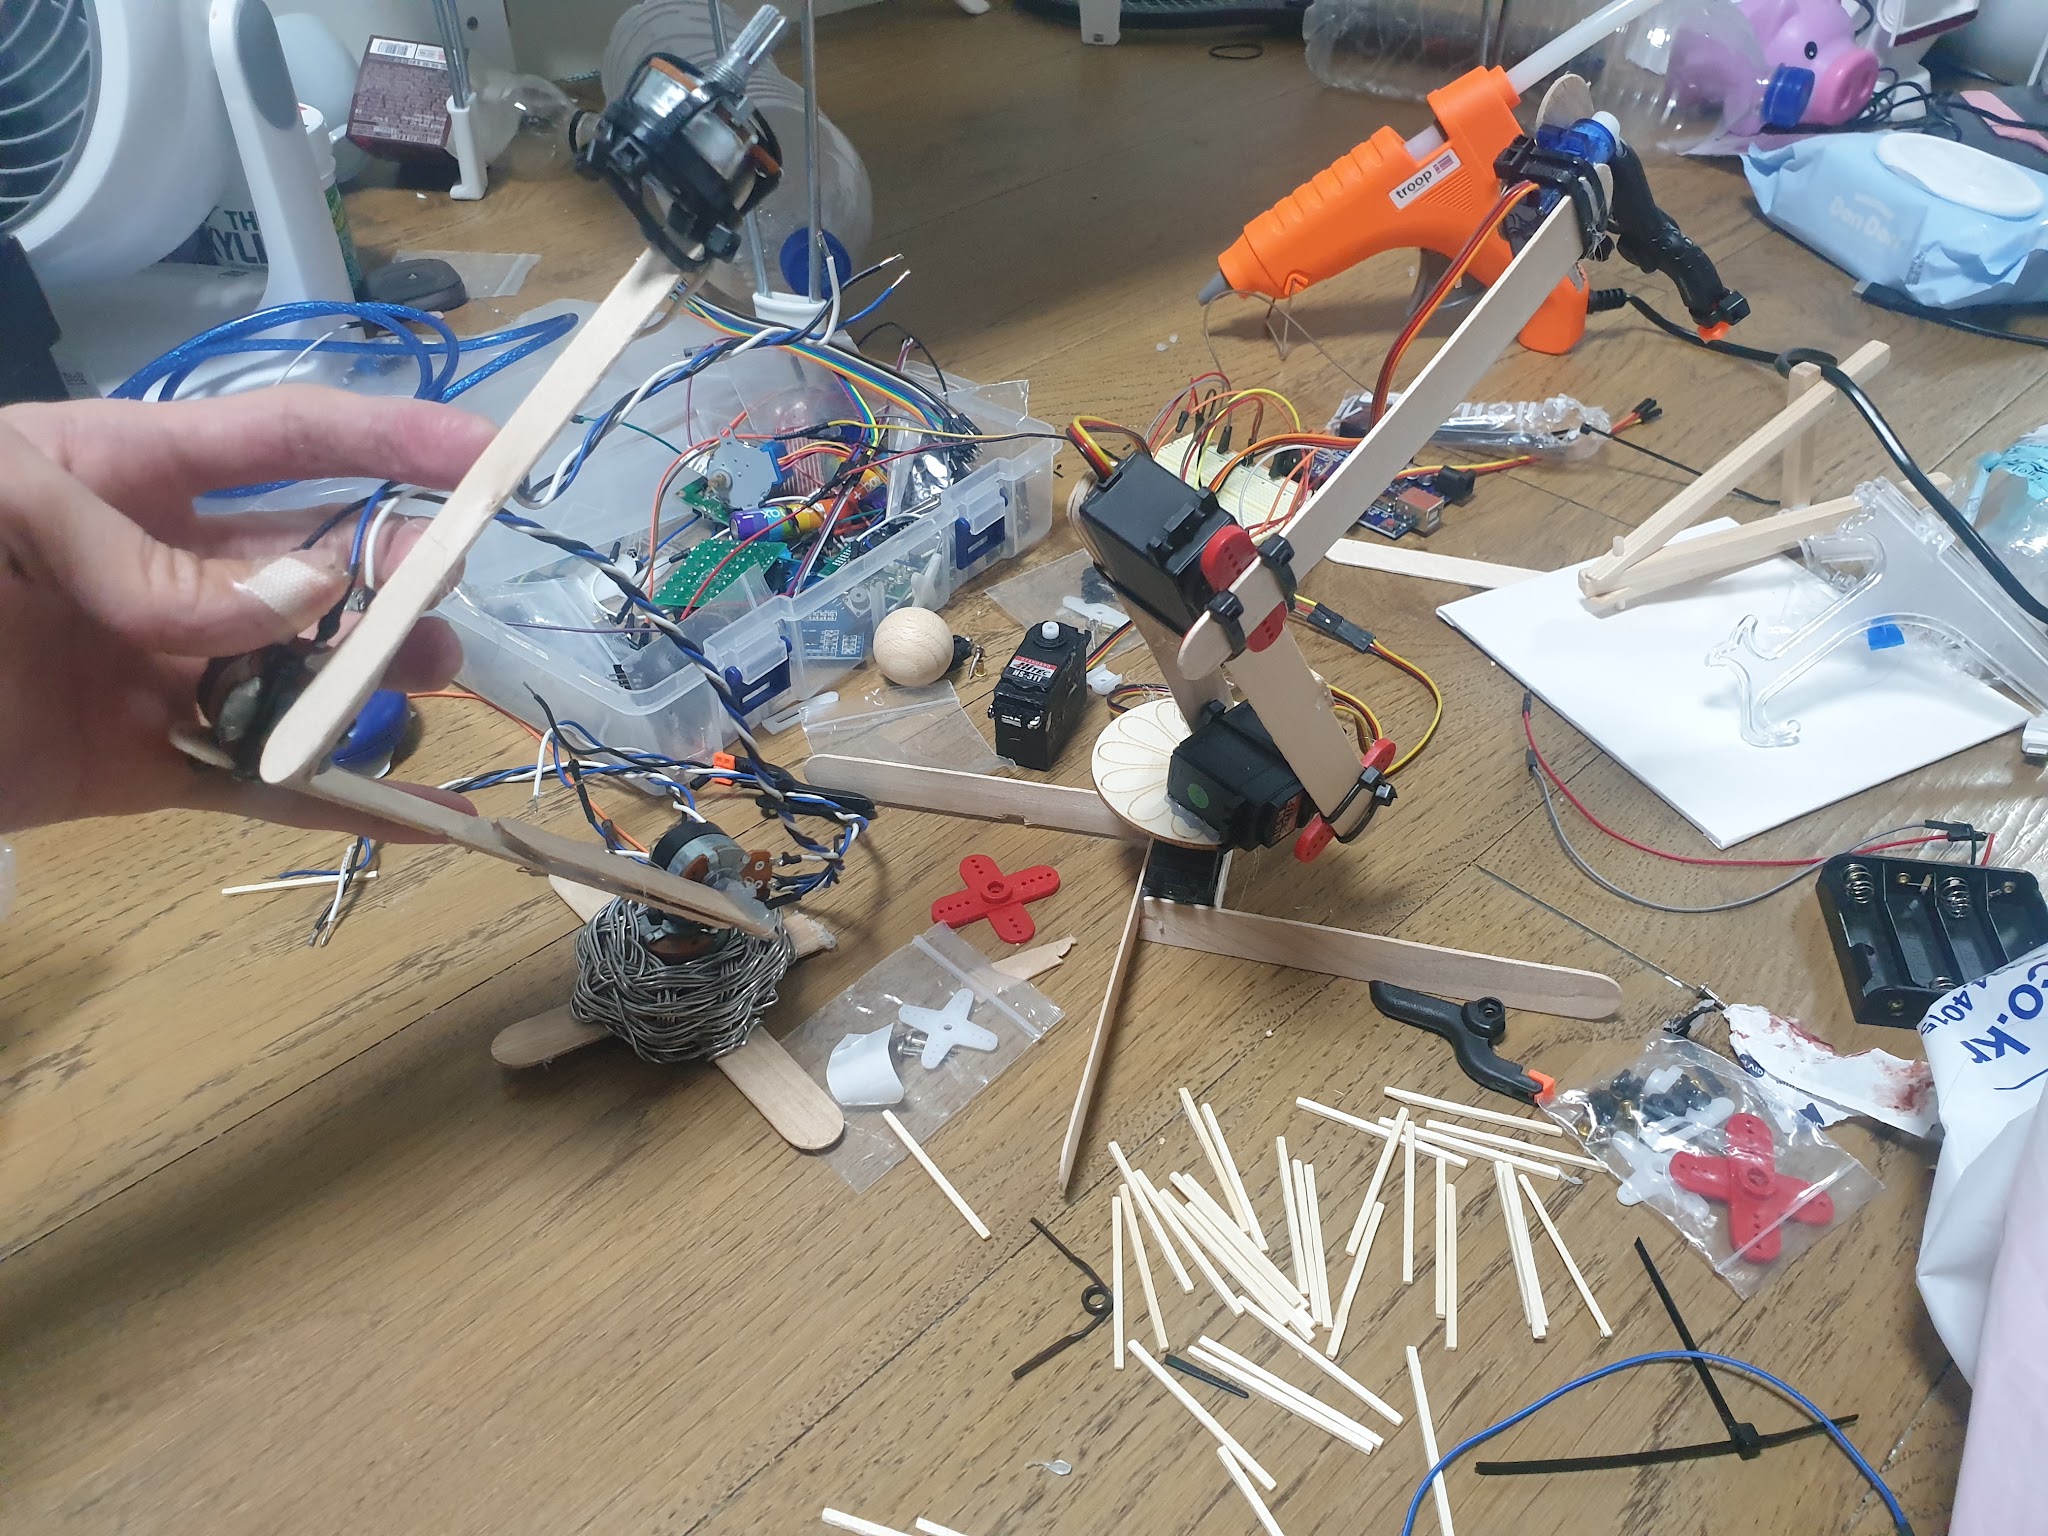
Shaping the movement
Inspired by Sisyphus, the project began with the idea of a robot repeatedly lifting a ball uphill. It developed into a painting system, using a paint-covered ball and a rotating canvas to turn repetition into a physical trace.
The wooden robot was built around Arduino and servo motors. A separate dummy arm fitted with potentiometers let its movement be shaped by hand. The work note records how those angle values were captured and used to reproduce movement on the actual arm.
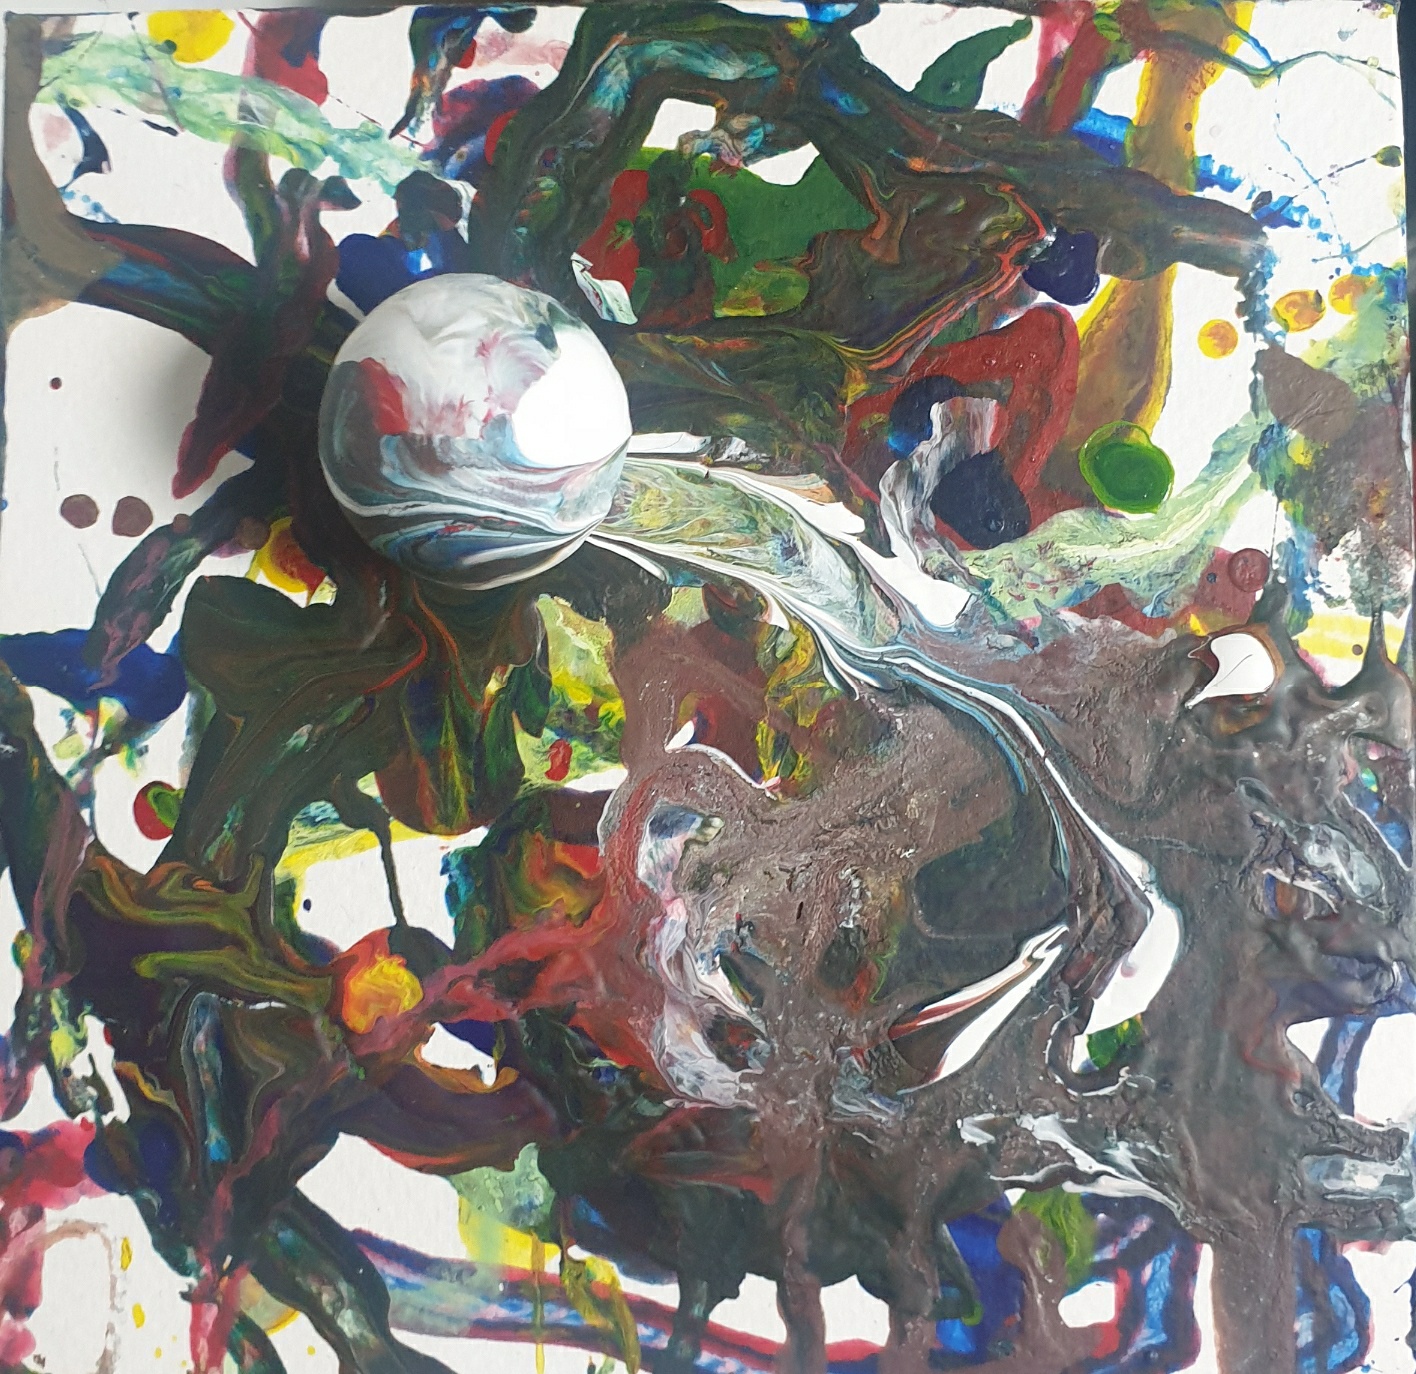
A record of movement, made visible
Paint carried by the ball leaves overlapping marks on the surface. The resulting painting holds the traces of the system and its maker.